Skip to content

ROBOTICS · LULEÅ, SWEDEN

Akash Patel

Postdoctoral researcher · Robotics & AI, Luleå University of Technology

PhD in autonomous robotic exploration, defended November 2025

I work on autonomy for aerial and ground robots in places without GPS, connectivity, or maps: underground mines, natural caves, and planetary analogs. The planners and mappers from my research have flown missions in an Icelandic lava tube and in operating mines, and the code is public on GitHub.

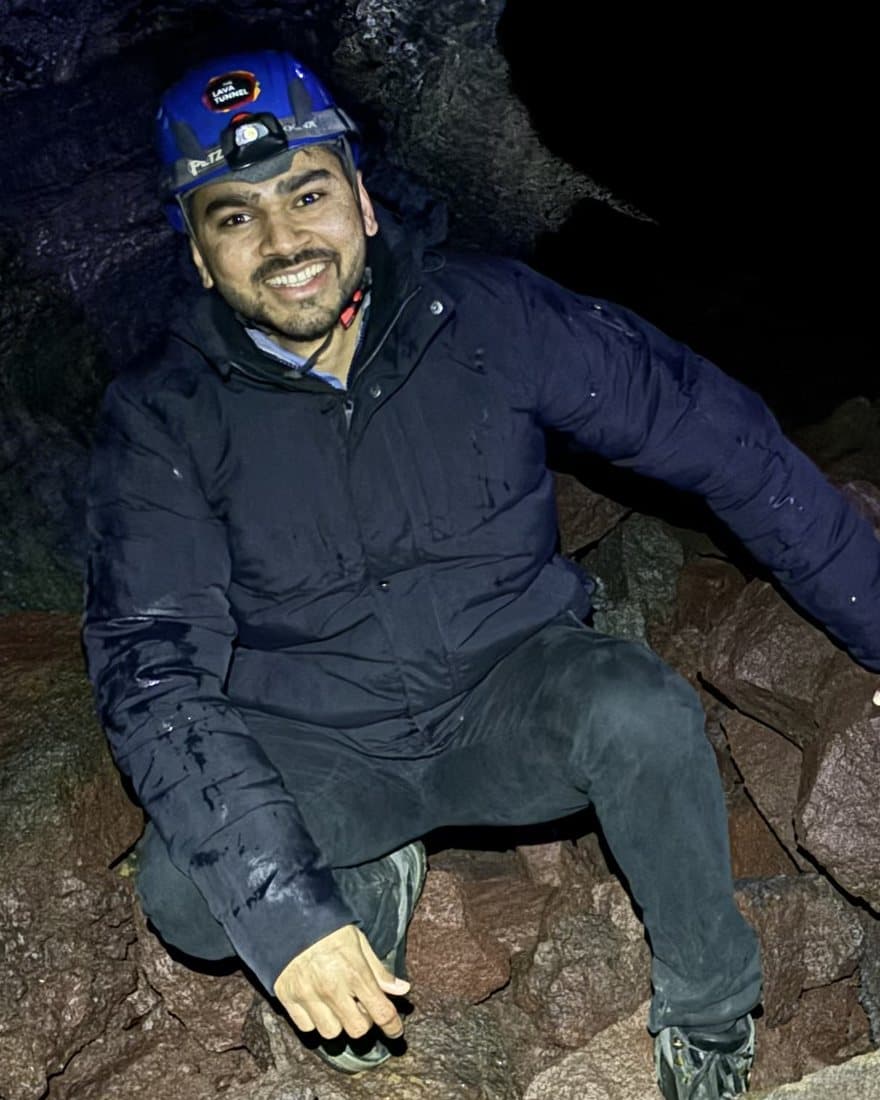
Akash Patel inside a lava tube in Iceland, wearing a helmet and headlamp
>1 kmof lava tube mapped over several autonomous flights
20+field deployments underground
3EU research programs

FIELD HIGHLIGHT

Autonomous exploration of a lava tube in Iceland

Over a series of flights, a drone explored a natural lava tube without a pilot or a prior map. The flights together covered more than a kilometre of passage and produced one 3D reconstruction.

video

The footage shows one of the flights in and the 3D reconstruction assembled from the campaign. Each flight ran from the entrance to its turnaround point and back with no pilot input. To our knowledge this was the first fully autonomous exploration of a natural lava tube. Lava tubes are also the closest terrestrial analog to caves on the Moon and Mars, the setting of my 2023 Advances in Space Research paper on lava-tube exploration with a Mars coaxial quadrotor.

LOCATION
Lava tube, Iceland
MAPPED
More than 1 km of tunnel over several flights
ONBOARD
All autonomy on the vehicle; no GPS, no pilot

Selected publications

Real-time exploration planning, traversability, and scene understanding for robots operating underground. Links go to the published version, the code, or the field video.

Full selected list · 20 papers

Funded, field-tested research

Horizon Europe and Horizon 2020 projects that put drones and ground robots into active underground mines, with industry partners including LKAB and Epiroc.

Work in the field

Field campaigns in operating mines, vertical shafts, and natural caves. Each entry names the environment and what the robot completed there.

  1. msn-001Field-provenpinned

    First autonomous lava-tube exploration

    Lava tube, Iceland · Field campaign

    Fully autonomous aerial exploration and mapping of a natural lava tube. More than 1 km of passage covered over several flights, each from the entrance to its turnaround point and back, with no GPS and no pilot.

  2. msn-002Field-proven

    Post-collapse rockfall assessment

    Iron-ore mine, Northern Sweden · Field campaign

    Autonomous mapping and inspection of rockfall zones after a roof collapse in an operating iron-ore mine. The survey of the affected area was produced before any person entered it.

  3. msn-003Field-proven

    Autonomous vertical shaft inspection

    Vertical mine shaft · NexGen SIMS

    Full autonomy in vertical shaft exploration with high-fidelity 3D reconstruction in real underground conditions.

  4. msn-004Field-proven

    Post-blast gas-measurement missions

    Underground mines · Journal work

    Autonomous post-blast gas-measurement runs in underground mines. Crews re-enter when the readings at the face show the air is clear.

  5. msn-005Field-proven

    Underground exploration & waypoint trials

    Nordic mines, potash operations · Multi-year

    Years of underground exploration and waypoint-navigation trials with Nordic mining companies, a mining-equipment manufacturer, and a European potash operator across EU- and industry-funded projects.

Software & open source

The planners, mappers, and control bridges behind the deployments. Each card states whether I authored or co-authored it; all are ROS-based and were run in the field.

RUNS ON

ROS / ROS2C++PythonPX4NMPCSLAM / LiDARGTSAM-class estimationDockerLinux

WORKS WITH

RESPLESuperOdomwavemapvoxbloxlidar_situational_graphsnmpc_px4_ros2GenesisCloudPeek

Education & teaching

  1. PhD · Autonomous Robotic Exploration & Path Planning

    Luleå University of Technology · Luleå, Sweden · 2021 to Nov 2025

    Autonomous exploration and path planning for UAVs and legged robots in GPS-denied environments: underground mines, caves, and planetary analogs. The thesis work shipped as field-tested software and was validated in real subterranean deployments. Defended November 2025.

  2. M.Sc. · Space Science & Technology (Erasmus Mundus SpaceMaster)

    Luleå University of Technology · Luleå, Sweden · 2018 to 2020

    Joint program across European partner universities covering space physics, orbital mechanics, and autonomous robotics. Thesis: design, modeling, and control of a coaxial quadrotor for the Martian environment.

  3. B.Tech. · Aerospace Engineering

    UPES, Dehradun · Dehradun, India · 2014 to 2018

    Focus on aerodynamics, propulsion, and control of aerial vehicles. Final-year project: design and simulation of a UAV for flight in Mars' thin atmosphere and reduced gravity.

R7010E Robotics

Course teaching at Luleå University of Technology.

MSc thesis supervision

Supervising Master's students on autonomy, mapping, and field robotics.

Get in touch

Write to me about research collaboration, thesis supervision, or underground operations. I answer every message myself.

aaka.patel@hotmail.com